Hyomuk Kim
I am a Master’s student in Electrical and Computer Engineering at UC San Diego (graduating March 2027), specializing in Intelligent Systems, Robotics, and Control (EC80). I recently joined the Existential Robotics Lab (ERL), where I am supervised by Professor Nikolay Atanasov. I am looking for full-time roles in robot perception, SLAM, manipulation, and robot learning starting in spring 2027.
Click to expand my past journey
Prior to joining UC San Diego, I was a Staff Engineer at the Robot Center of Samsung Research, where I focused on mobile robotic navigation. Working under the guidance of Junghyun Kwon and Aron Baik, I specialized in visual SLAM, 3D localization, mapping, and robust motion planning.
My research extends beyond robotics into applied AI. At Samsung's Global AI Center, advised by Chanwoo Kim, I engineered a Neural Text-To-Speech (TTS) engine—executing the entire pipeline from data collection and model training to C++ deployment. I also contributed to projects involving neural networks for Brain-Machine Interfaces (BMI) and command recommendation engines for AI agents.
Earlier in my career, I built a strong foundation in hardware and product development. I spent 5 years at Samsung's Visual Display Division, validating circuit systems for flagship TVs. Additionally, I led a 6-member team at C-Lab as a Project Manager, spearheading the development of a cross-device content archive platform.
News
- [Oct. 2026] I am on the job market for full-time roles in robot perception, SLAM, manipulation, and robot learning, starting spring 2027.
- [Oct. 2026] Started working on vision-language-action (VLA) policies for mobile manipulation with a Reachy 2 robot at ERL.
- [Apr. 2026] Joined the Existential Robotics Laboratory (ERL) and started research on non-prehensile manipulation with an xArm6 arm.
- [Sep. 2025] I have started my Master’s degree in ECE at UC San Diego!
Research Interests
I want to build robots that perceive, plan, and act reliably in unstructured environments. I am most interested in combining classical estimation and model-based control with learned policies, so that each covers the other’s weak spots.
- Robot Perception: Visual SLAM, State Estimation & Sensor Fusion, 3D Scene Understanding
- Planning & Control: Sampling-Based MPC (MPPI), Non-Prehensile Manipulation, Mobile Robot Navigation
- Robot Learning: Imitation Learning (Diffusion Policy), Vision-Language-Action Models, Learning-Augmented Control
Projects
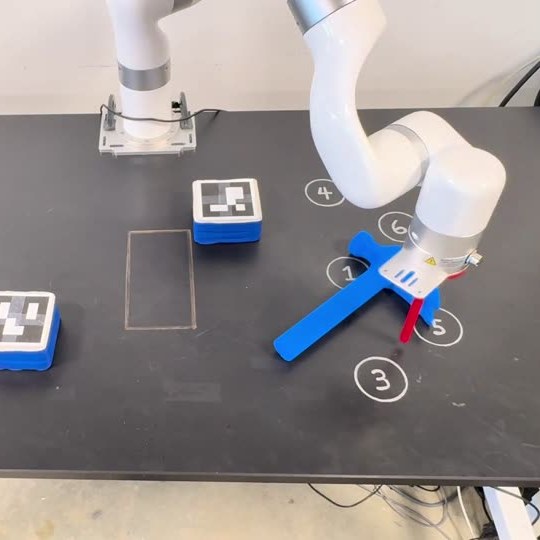
Non-Prehensile Manipulation among Obstacles with Sampling-Based MPC
Existential Robotics Lab, UC San Diego (Apr 2026 – Present)
Research on pushing objects to goal poses among obstacles with an xArm6 manipulator using sampling-based model predictive control. I verified the controller implementation, built the perception and experiment pipeline, and ran the real-robot experiments behind the results. The paper is under review; details will follow after the review period.
Tech: MPPI, Perception, Real-Robot Experiments
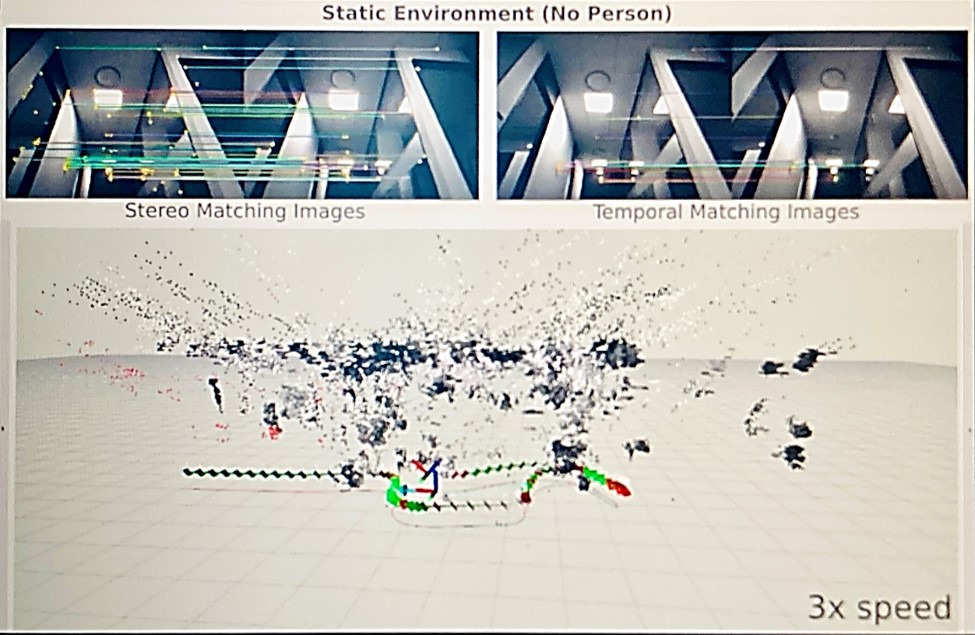
Visual SLAM for Autonomous Mobile Robots
Samsung Research (Jan 2022 – Feb 2024)
Co-designed from scratch and implemented in C++ the visual SLAM module of a new AMR platform: ORB feature matching, pose estimation, and multi-threaded local bundle adjustment with Ceres. It ran under ROS2 on a Qualcomm RB5 with a RealSense D435 and was tested on mobile robots in indoor environments.
Tech: C++, ROS2, Ceres, Eigen, OpenCV
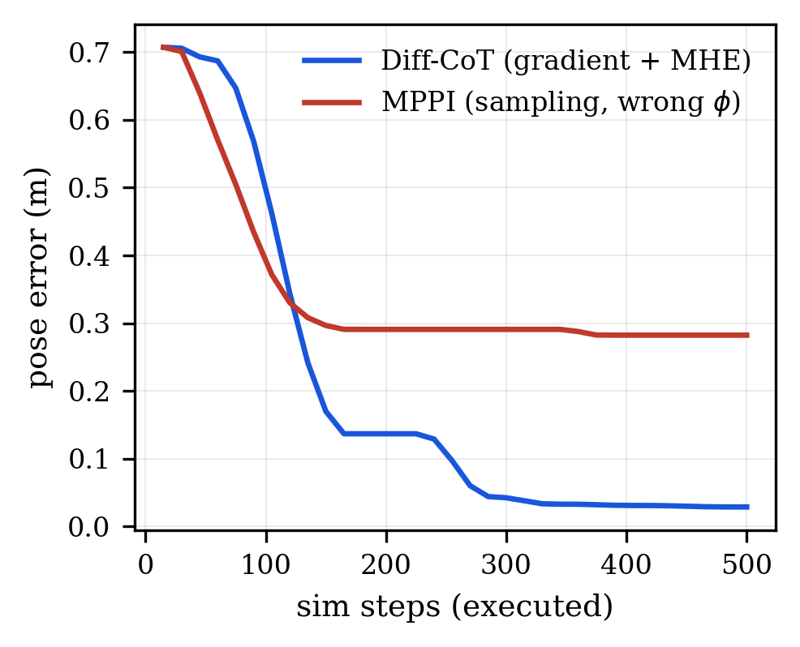
Simultaneous System Identification and Control for Object Pushing via Differentiable Physics
UC San Diego (Apr 2026 – Jun 2026)
Coupled a receding-horizon differentiable MPC with a moving-horizon estimator inside one differentiable MuJoCo MJX model, identifying an object's friction and center of mass online while pushing it to a goal. On an asymmetric L-block, online identification reached the goal where MPPI planning on a wrong model stalled.
Tech: JAX, MuJoCo MJX, Differentiable MPC, Moving Horizon Estimation
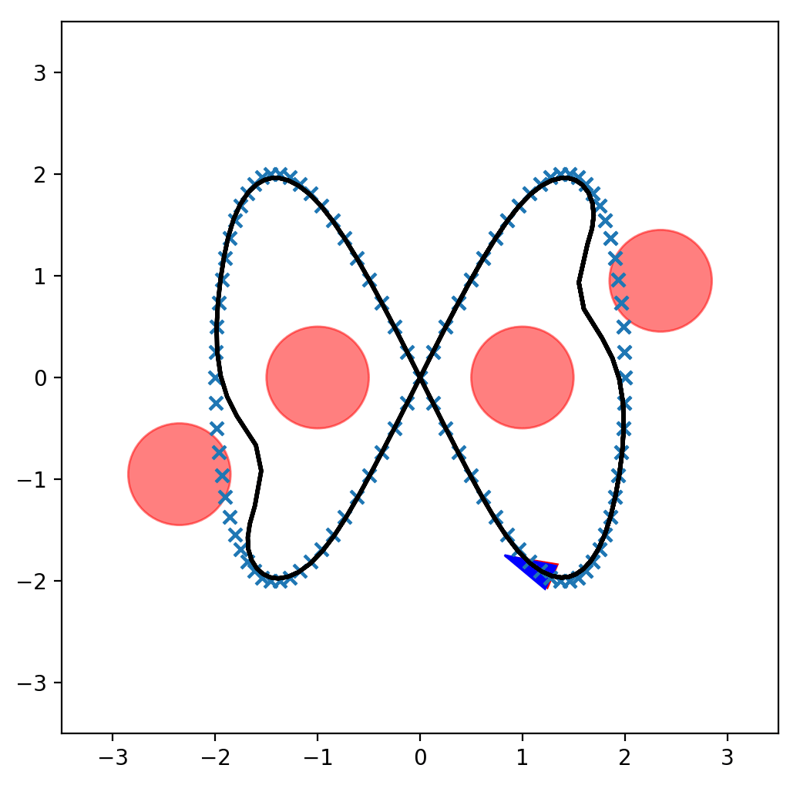
Safe Trajectory Tracking: Receding-Horizon CEC vs. Generalized Policy Iteration
UC San Diego (May 2026 – Jun 2026)
Compared online nonlinear MPC (certainty equivalent control in CasADi) with offline generalized policy iteration on an adaptive grid for a differential-drive robot tracking a figure-eight among obstacles. CEC had about 3x lower tracking error and no collisions at 25 ms per step, while GPI controlled the robot with 0.13 ms table lookups.
Tech: Python, CasADi, Dynamic Programming, Stochastic Optimal Control
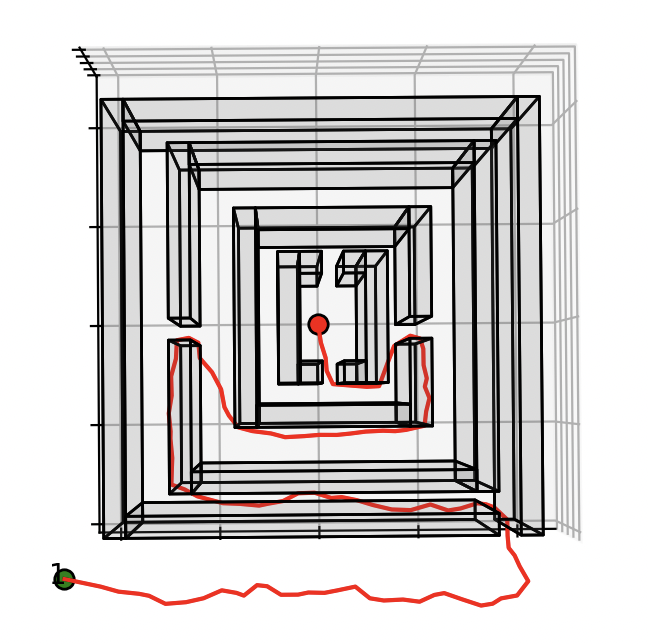
Real-Time RRT* Motion Planning in 3D with Moving Goals
UC San Diego (Apr 2026 – May 2026)
Implemented RRT* for 3D environments with path smoothing and R-tree spatial indexing, and reused the search tree across moving goals instead of rebuilding it. Reached eight sequential goals in about 0.05 s in total and converged to within 0.28 m of the shortest path.
Tech: Python, RRT*, R-tree
Action Diffusion Policy: Generative Imitation Learning for Manipulation
UC San Diego (Jan 2026 – Mar 2026)
Implemented a Conditional Denoising Diffusion Policy using a 1D Temporal U-Net to solve mode-averaging in explicit Behavior Cloning. Achieved an 81.33% success rate on contact-rich manipulation tasks in the Push-T environment by integrating EMA weight smoothing and Action Chunking.
Tech: PyTorch, Diffusers, Gymnasium, LeRobot
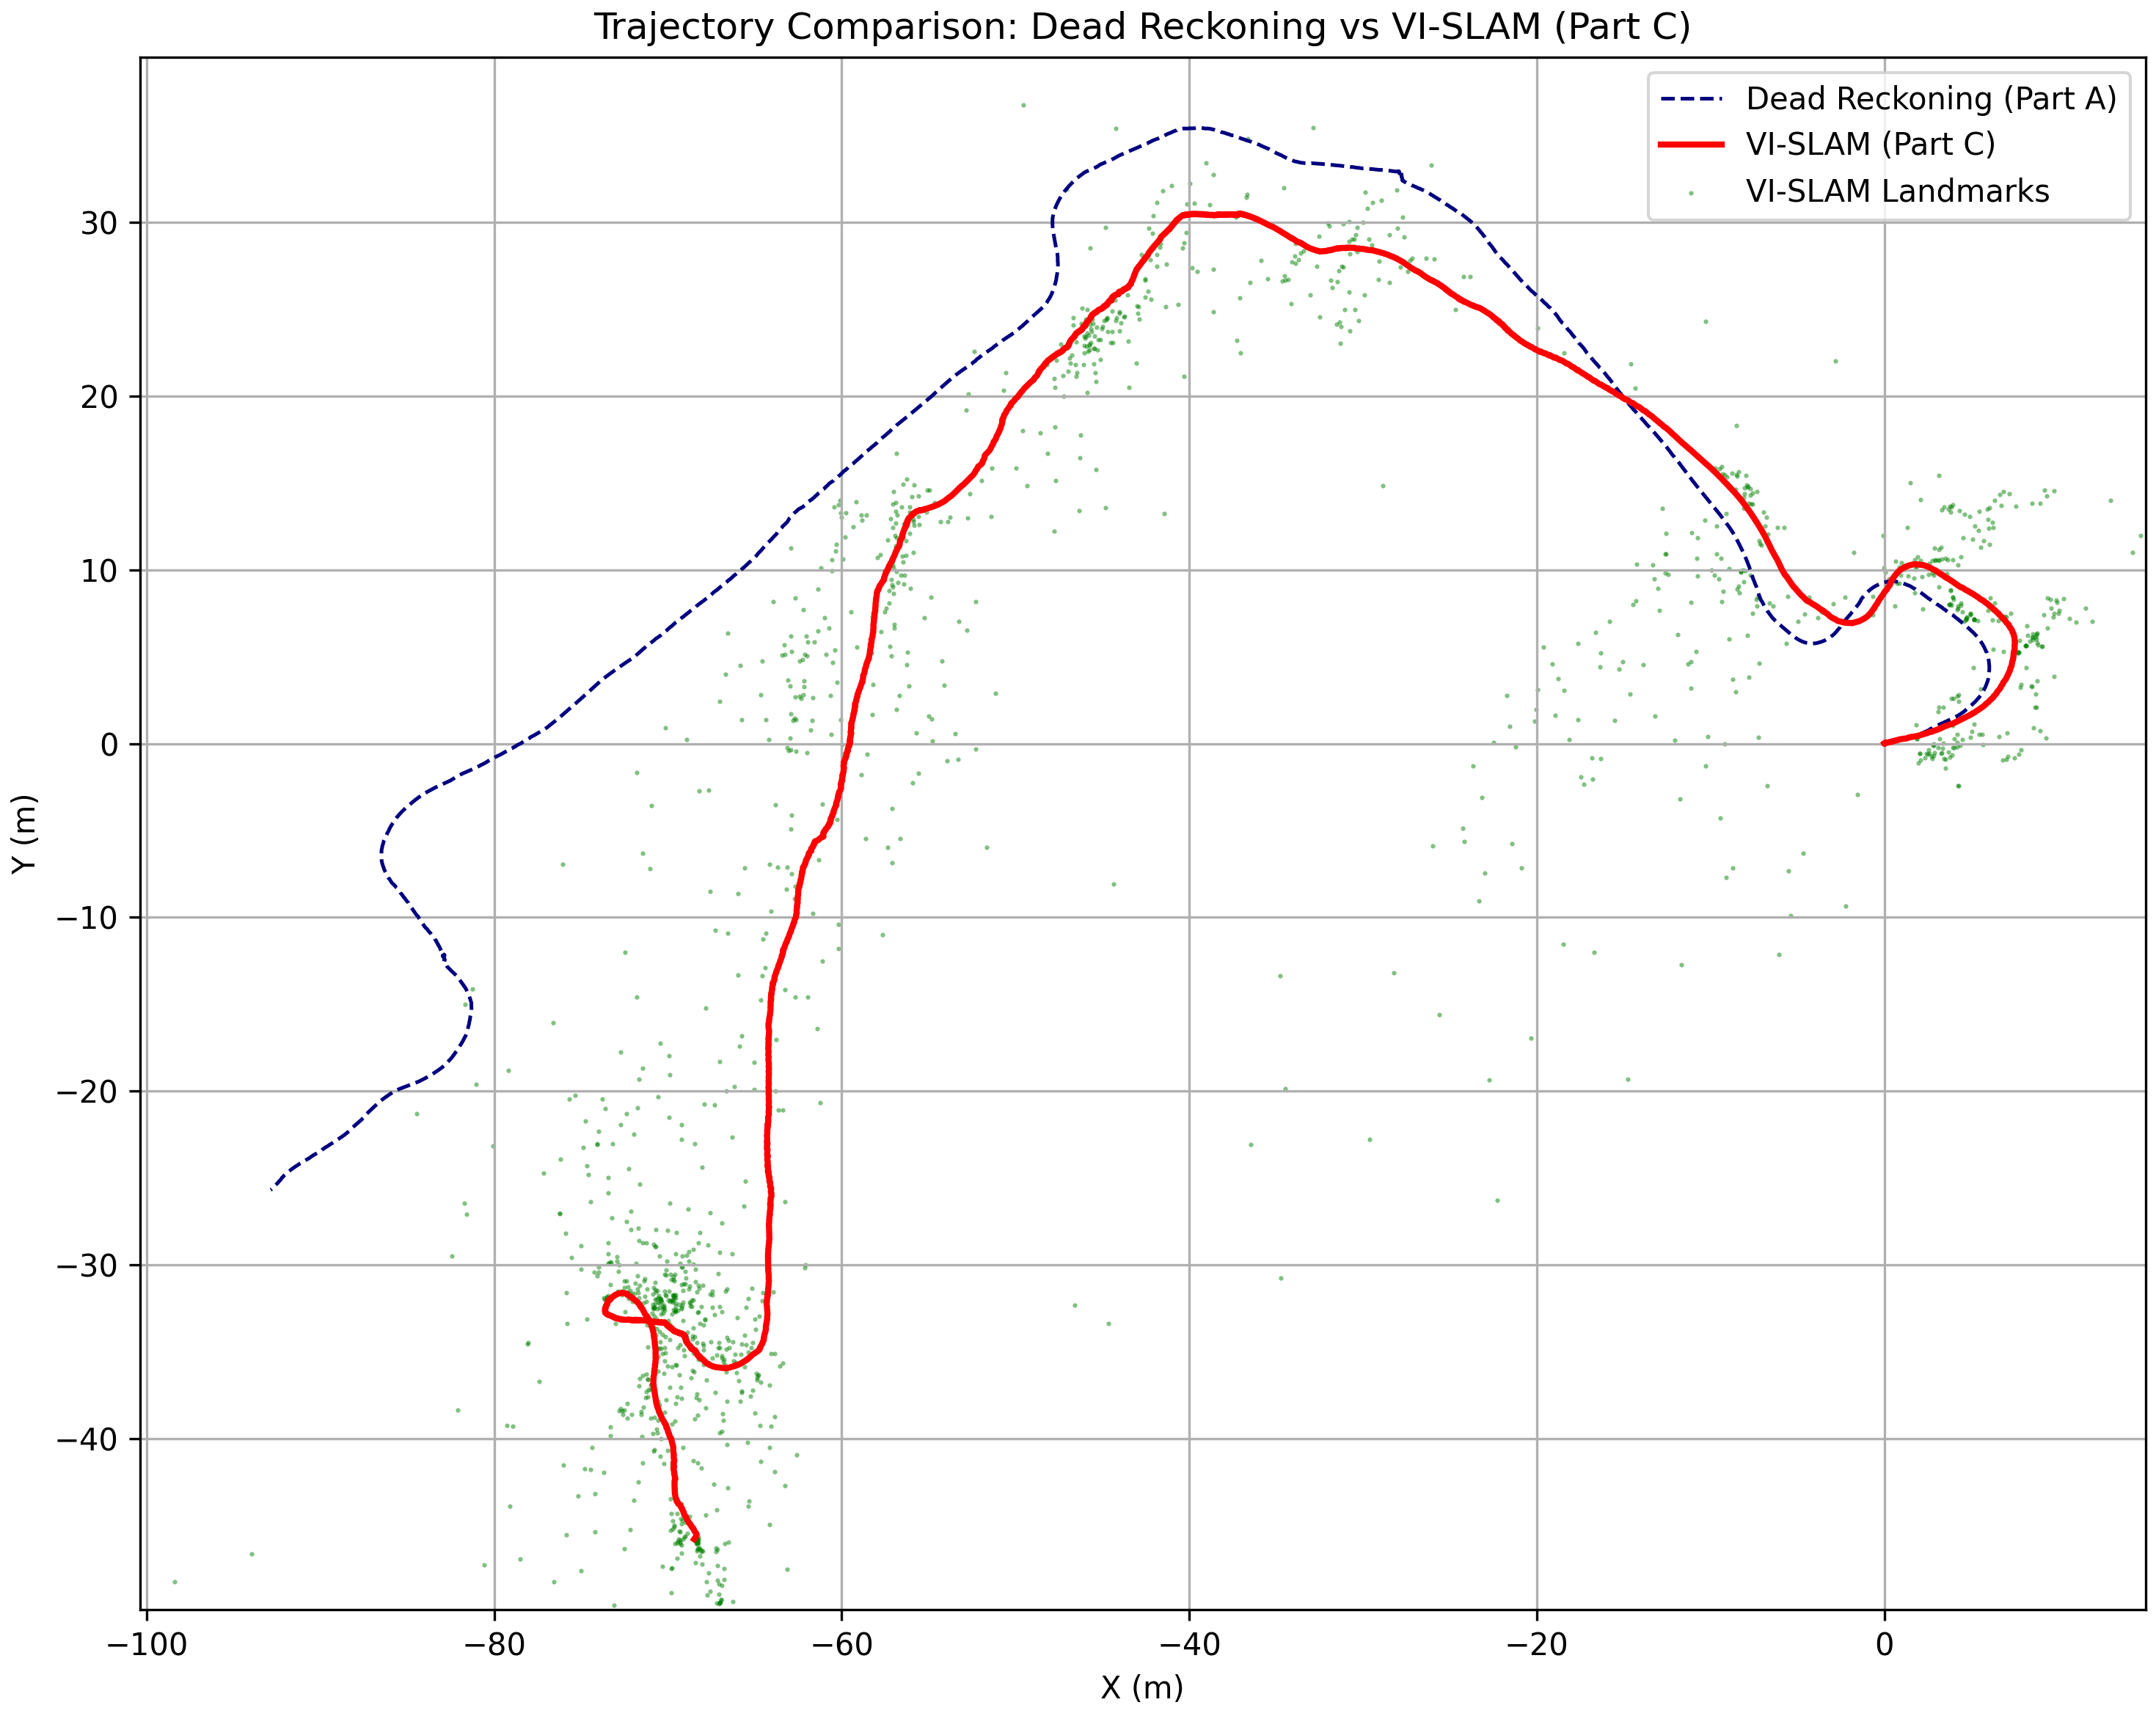
6-DOF Visual-Inertial SLAM Using Extended Kalman Filter
UC San Diego (Feb 2026 – Mar 2026)
Built a VI-SLAM system fusing high-rate IMU SE(3) kinematics with stereo vision using a Full EKF. Optimized the bottleneck via sparse batch updates and analyzed filter limitations against dynamic outliers (e.g., deceptive static objects) in complex datasets.
Tech: Python, Lie Algebra, Stereo Vision
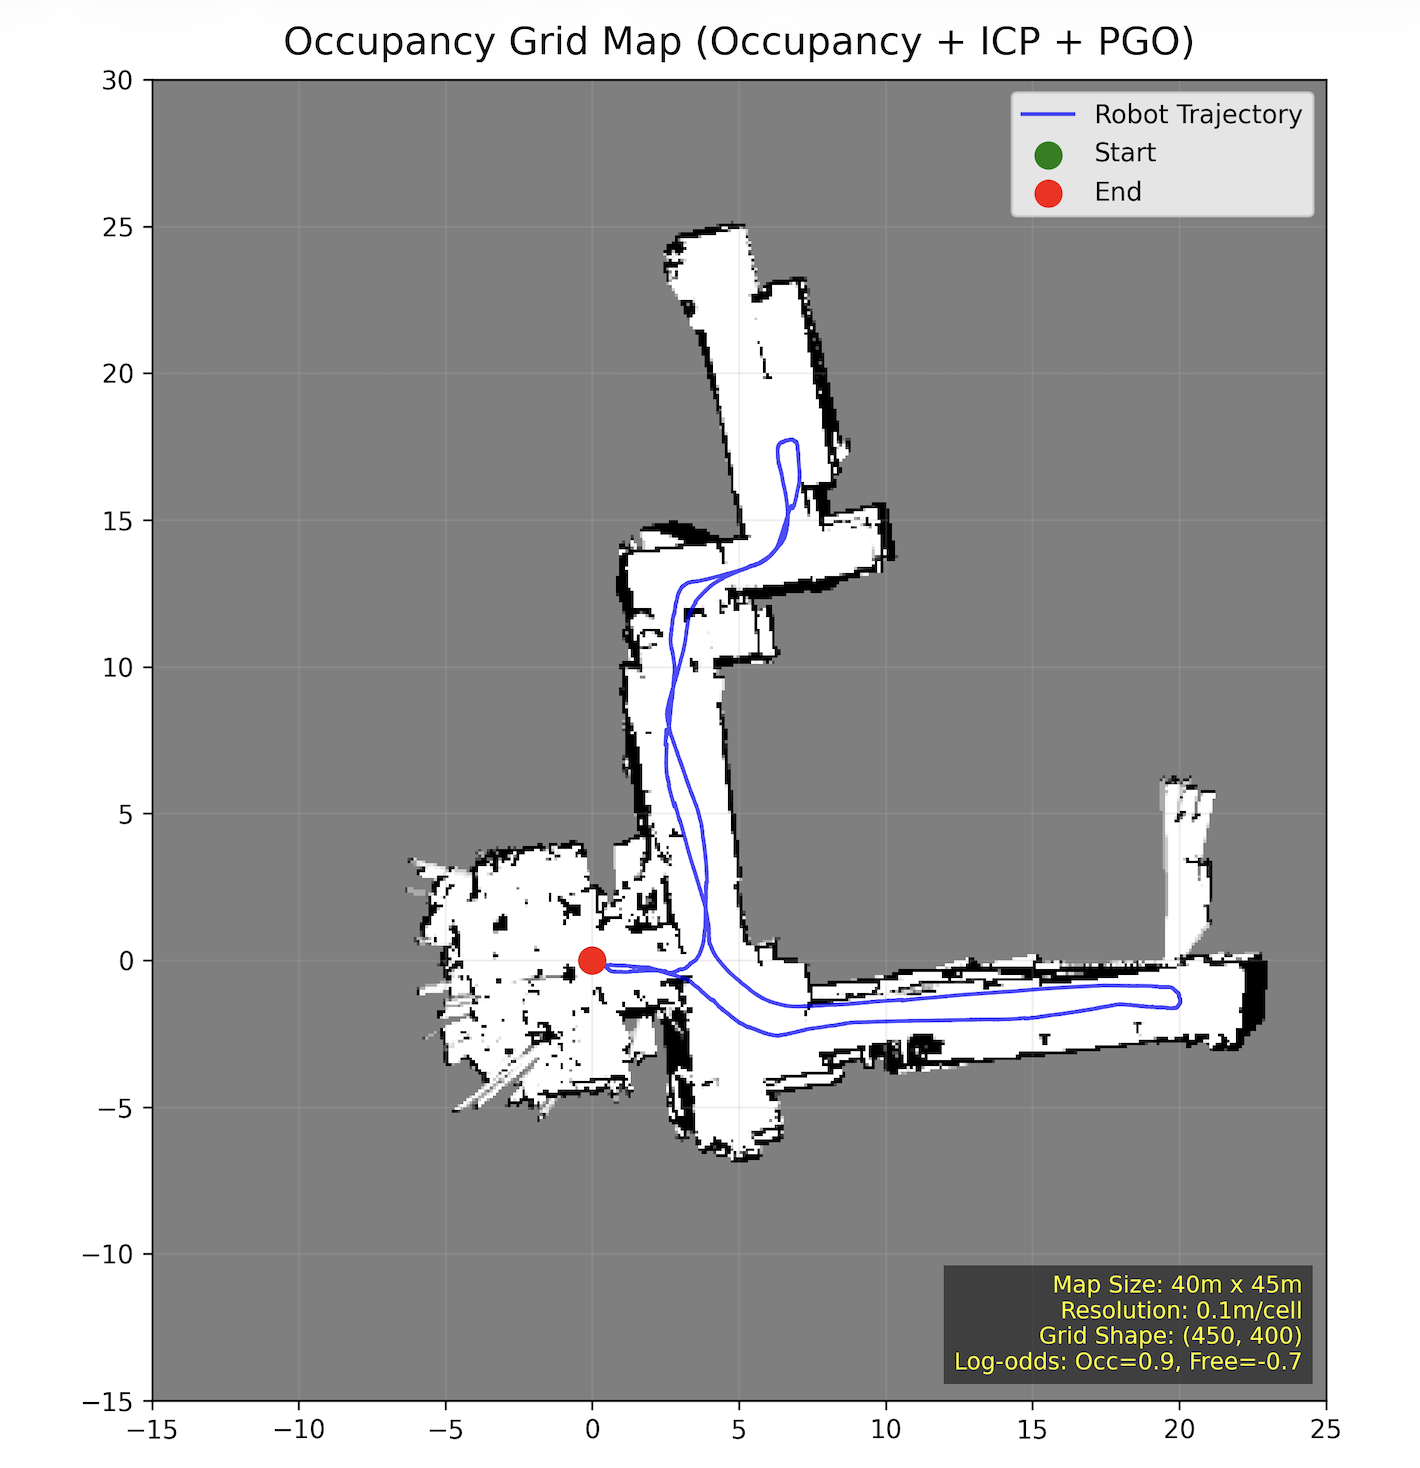
2D LiDAR SLAM & Pose Graph Optimization (PGO)
UC San Diego (Feb 2026)
Developed a SLAM pipeline for a PR2 robot fusing wheel encoders, IMU, and LiDAR. Implemented 2D ICP for scan-matching and robust PGO using GTSAM with Huber M-estimators to successfully reject false loop closures caused by the aperture problem.
Tech: GTSAM, Python, Sensor Fusion
Mobile Manipulation Control Pipeline for KUKA youBot
UC San Diego (Feb 2026 – Mar 2026)
Designed a kinematic software pipeline featuring a task-space feedback controller and an 8-segment trajectory generator for complex pick-and-place tasks. Addressed singularity avoidance, integral windup, and joint velocity saturation.
Tech: Python, CoppeliaSim, Kinematics
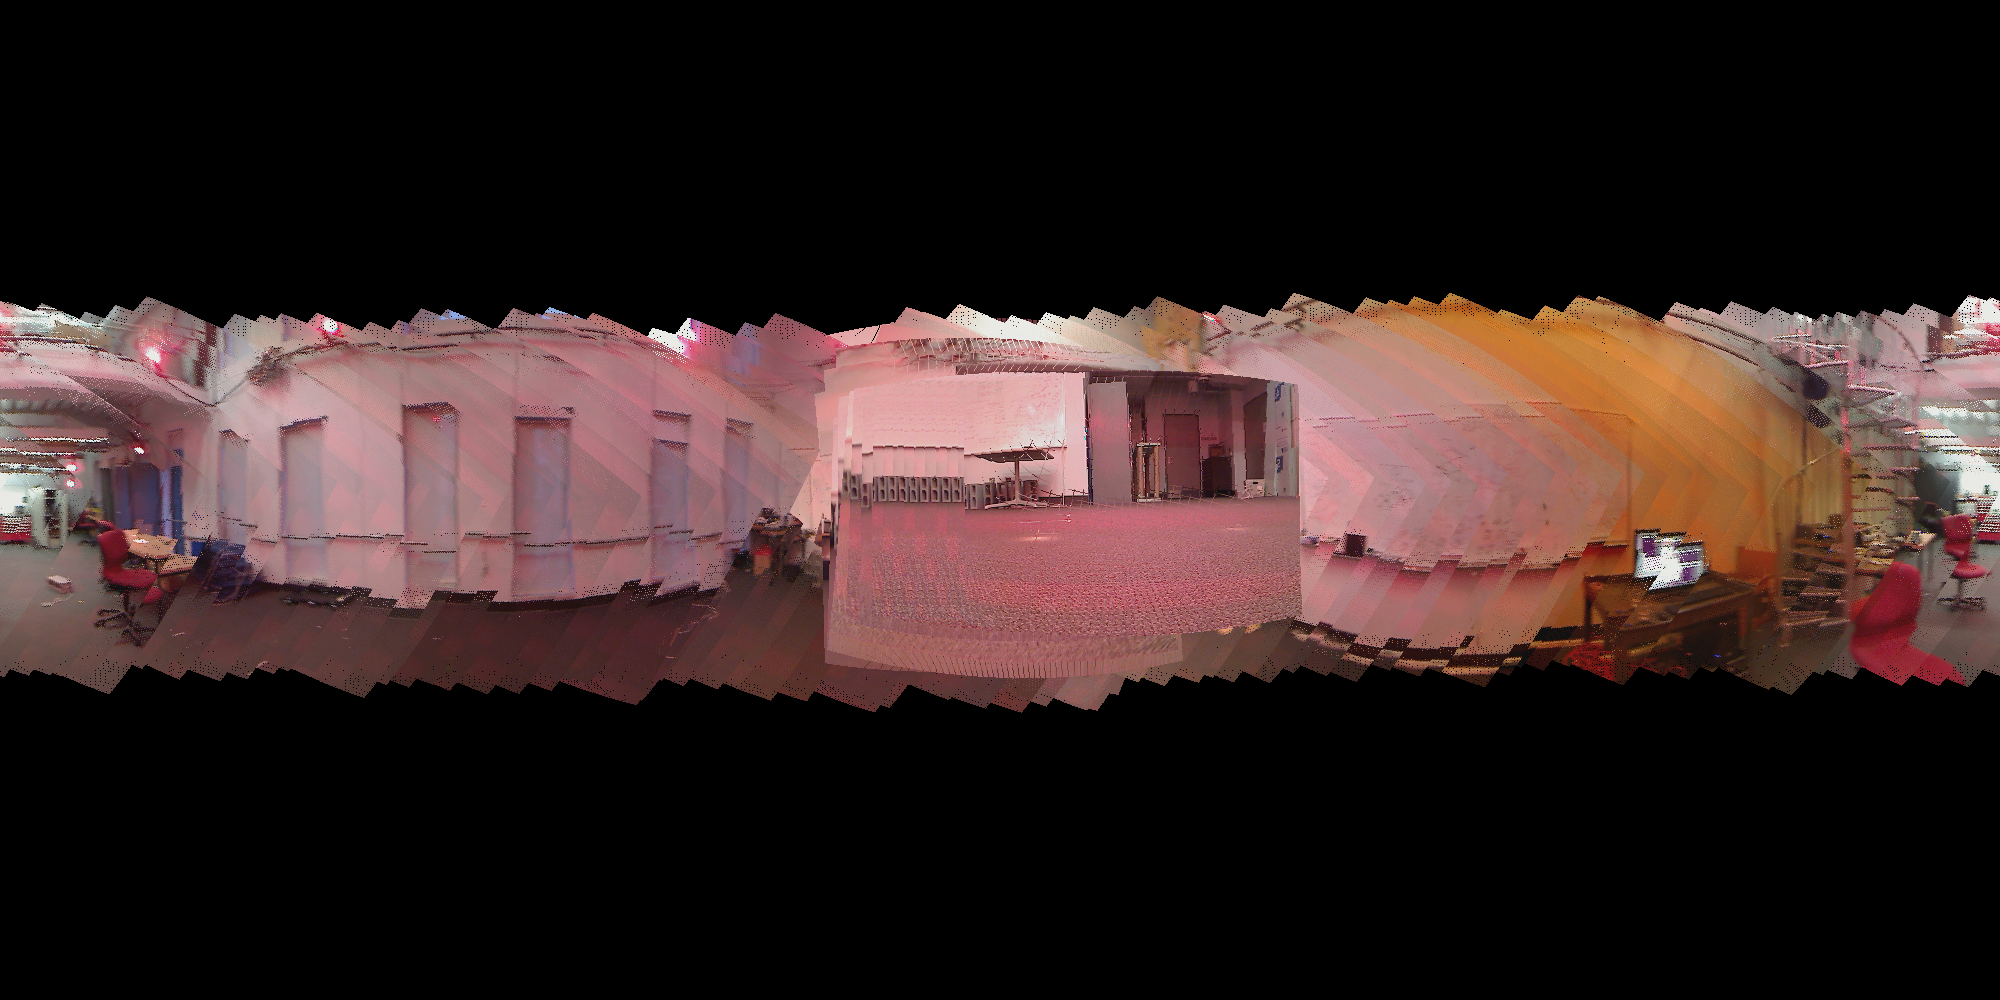
3D Orientation Tracking & Panorama Reconstruction
UC San Diego (Jan 2026)
Formulated an optimization-based state estimator on the unit quaternion manifold using Projected Gradient Descent (PyTorch) to fuse IMU kinematics. Reconstructed panoramic images by mapping pixel coordinates to spherical coordinates using estimated camera poses.
Tech: PyTorch, Optimization, Computer Vision
Experience
UC San Diego
La Jolla, CASamsung Research
Seoul, KoreaSamsung Electronics
Suwon, KoreaSelected Patents
Throughout my career as a robotics and hardware engineer at Samsung, I have authored and contributed to multiple patents, two of which have been granted in the US. Below are a few selected works:
- Robot System as a Mothership and Controller of Microbots. Hyomuk Kim, Aron Baik. US20240148213A1 (pending), May 2024.
- Robot Device Operating In Mode Corresponding To Position Of Robot Device And Control Method Thereof. Hyomuk Kim, Woojeong Kim, Jewoong Ryu, Mideum Choi, Aron Baik. US12560940B2 (granted), Feb 2026.
- Movable Robot And Controlling Method Thereof. Eunsoll Chang, Youngil Koh, Hyomuk Kim, Mideum Choi. US20230356391A1 (pending), Nov 2023.
- Method of Yield Planning for Mobile Robots. Mideum Choi, Hyomuk Kim, Jewoong Ryu, Aron Baik. US12468305B2 (granted), Nov 2025.